Name the operating arrangement before the interface
A conveyor enquiry can ask for robot integration without explaining what the product does during the robot operation. Does it arrive at a defined position and stop, or is the robot expected to work with it while the conveyor moves? State that intention at the start of the project brief.
Describe the product's presentation, the operation and the required receiving condition after the robot has finished. The phrase robot ready cannot replace those details. It may leave a conveyor supplier and a robot integrator pricing different operating arrangements while both believe they have answered the enquiry.
Keep the equipment references and intended format range together. If a robot or vision system has already been selected, identify the supplied configuration rather than a broad product family name.
Indexing and tracking describe different coordination
Dorner lists robotic picking among applications for its indexing and positioning conveying solutions. Universal Robots separately documents conveyor tracking as a function in which robot motion follows conveyor movement. Those manufacturer examples illustrate different operating descriptions; they do not establish compatibility between any two pieces of equipment.
Ask the integrator to identify the arrangement proposed for the actual job. For a stopped-product operation, ask how product presentation and the permission for the process are established. For a tracking proposal, ask how the selected system obtains the motion information it requires and identifies the relevant product.
Universal Robots' cited setup documentation includes encoder and conveyor configuration options for the named software range. Use the applicable manufacturer's documentation for the supplied system; this article does not provide a wiring, calibration or robot-programming procedure.
Keep product location separate from a belt-speed statement
A conveyor speed in a quotation is one item in the operating record. It does not by itself explain which product the robot should handle, how it is presented or what happens when the intended operation cannot be completed. Write the sequence around the actual product and process.
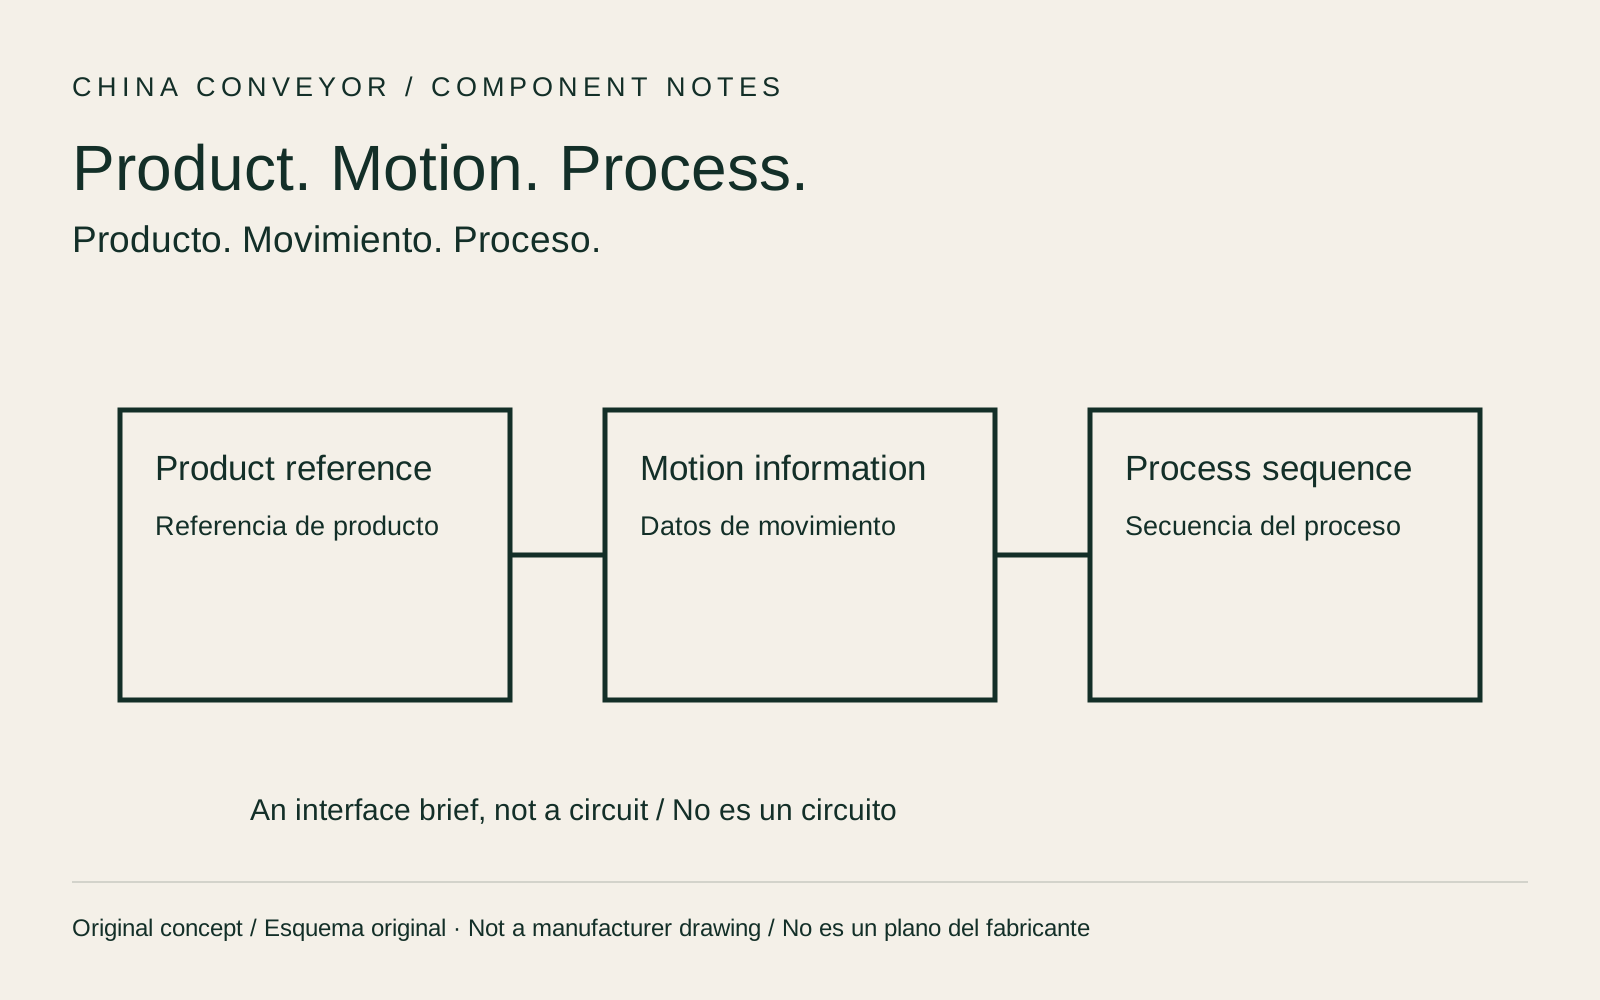
Ask the project teams to identify responsibilities for product detection, motion information, process permission and the receiving equipment. State the required response to a pause, missing product or unavailable receiver and have the responsible integrator define the implementation. Preserve unresolved interfaces in the project record rather than allowing an unnamed party to own them by implication.
If vision is included, have its supplier identify the conditions and formats represented by the proposal. A successful demonstration with one presentation should remain linked to that presentation in the acceptance record.
Demonstrate the coordinated operation
Agree a representative operating demonstration with the conveyor and robot teams before handover. Record the formats, sequence and conditions represented, with the approved equipment references and applicable instructions. Keep untested cases visible for later review.
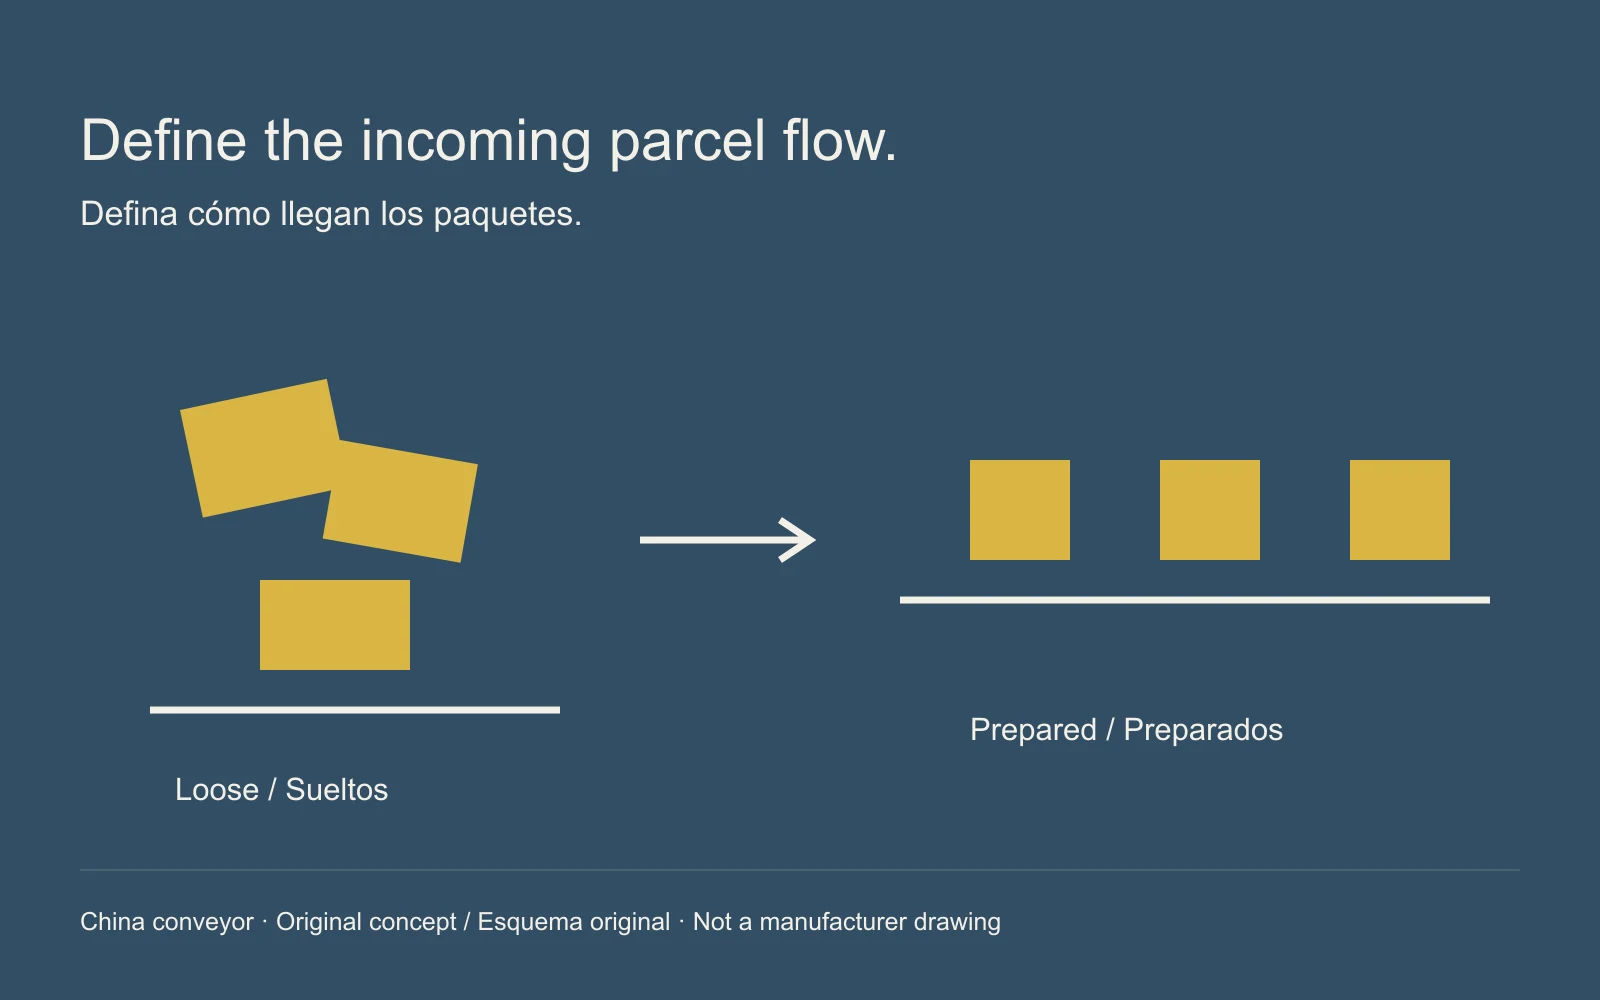
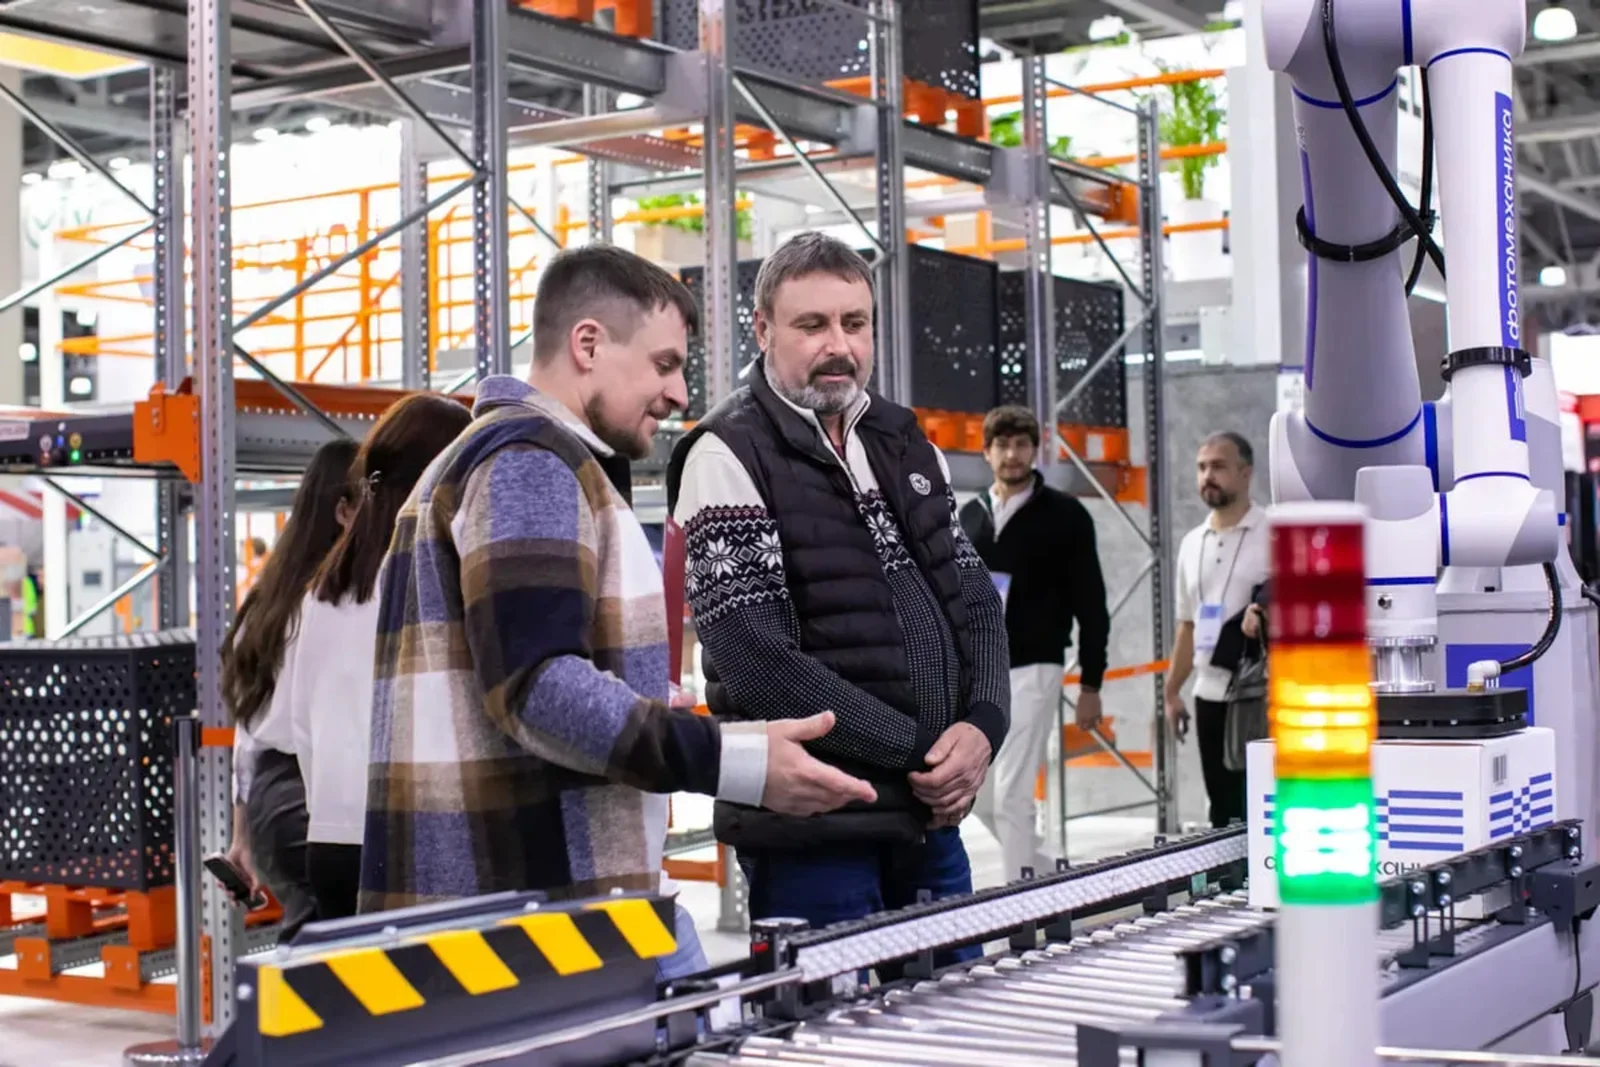
The exhibition photograph is contextual and does not identify a tested Dorner or Universal Robots installation. The original diagram describes the shared interface brief, without assigning a positional tolerance or cycle rate. The useful result is an agreed operation that both suppliers can describe, demonstrate and support.
Manufacturer announcements and our analysis are distinguished. Product claims require verification for the specific application.
Sources
Dorner — Indexing and positioning conveying systems ↗Primary application description includes robotic picking. No accuracy or cycle-time figure is adopted for an unspecified project.
Universal Robots — Conveyor tracking using encoder with digital pulses ↗Existing manufacturer application example describes robot motion following conveyor movement. Used as context, not a wiring or programming procedure.
Universal Robots — Conveyor tracking setup, SW 5.19 documentation ↗Existing version-specific documentation identifies encoder and conveyor configuration options. Used as interface context, not setup steps.